About

Xicheng Gong

宫西诚

Peking University · Incoming PhD student · Starting 2027

I am an incoming PhD student at the Academy for Advanced Interdisciplinary Studies, Peking University, starting in 2027 under the supervision of Prof. Yadong Mu. I am currently completing my undergraduate studies in Intelligent Science and Technology at PKU EECS.

I previously collaborated with Prof. Lin Shao at NUS, and I continue to work closely with Wenxuan Song. My research focuses on developing new model architectures for robotic manipulation. I aim to build robots that can learn transferable skills and generalize across tasks, environments, and embodiments.

Selected papers

2025 — 2026

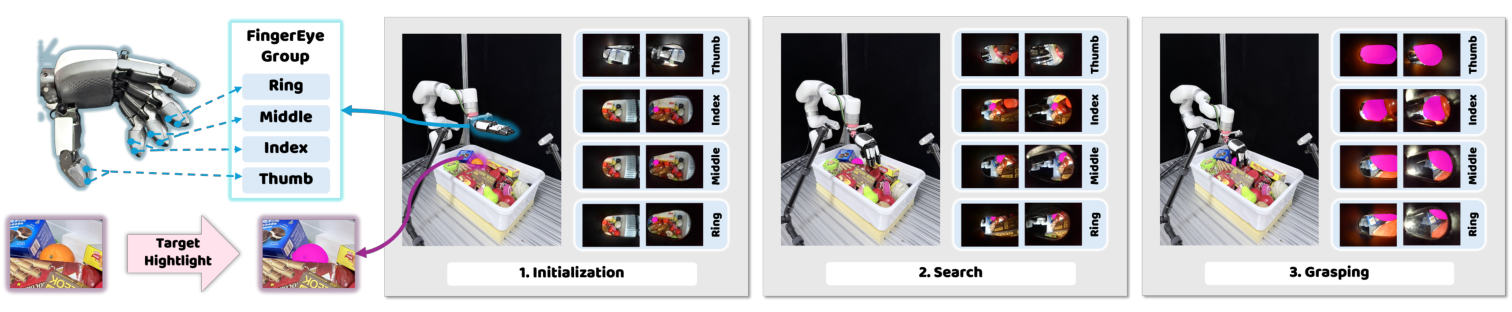
2026DexEyeGraspFingerEye cameras guide target search and dexterous grasping in dense clutter
ICRA 2027 · Submitted

DexEyeGrasp: Learning Dexterous Grasping in Clutter with FingerEye Observations

Co-first Author

Dexterous grasping in dense clutter using fingertip-camera observations, teacher–student learning, self-supervised geometric prediction, and residual visual adaptation for sim-to-real transfer.
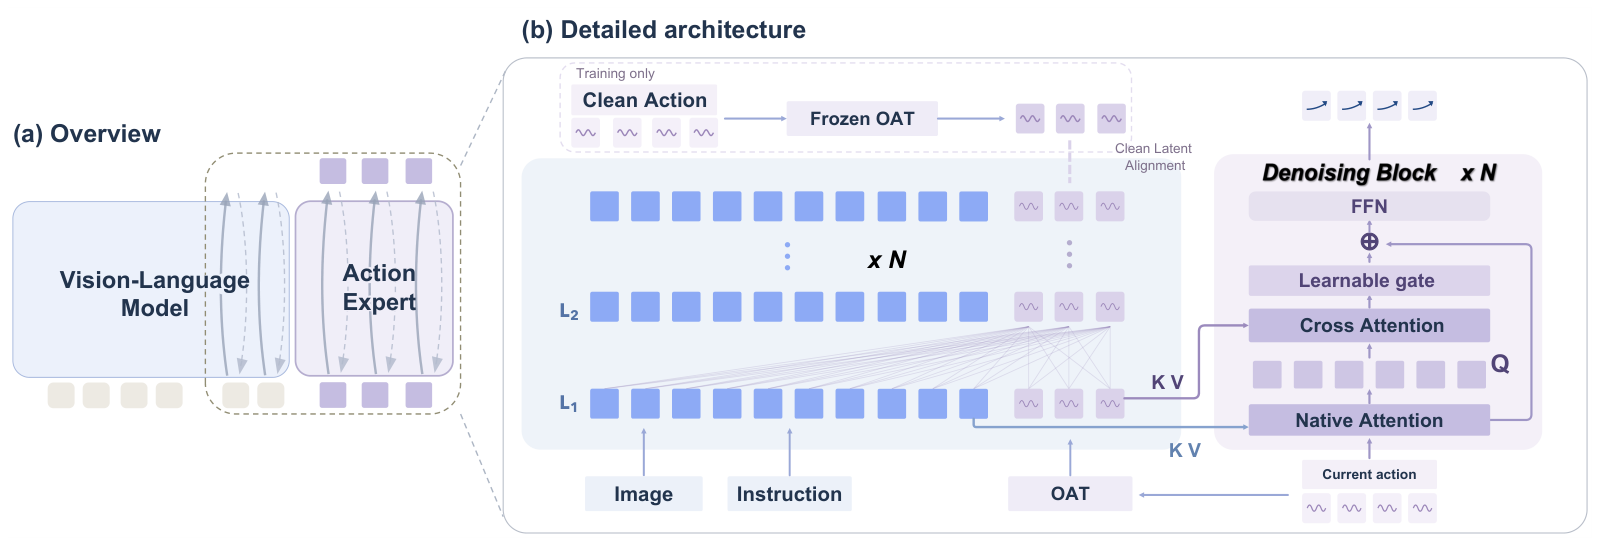
2026JADEJADE architecture: noisy-action latents enter the vision-language model and guide the action expert through gated cross-attention
ICLR 2027 · Under review

Vision-Language Models Are Joint Denoisers in Robotic Action Generation

JADE brings the vision-language model into the action denoising loop, using noisy action latents, gated cross-attention, and clean-latent supervision to jointly refine robot actions.

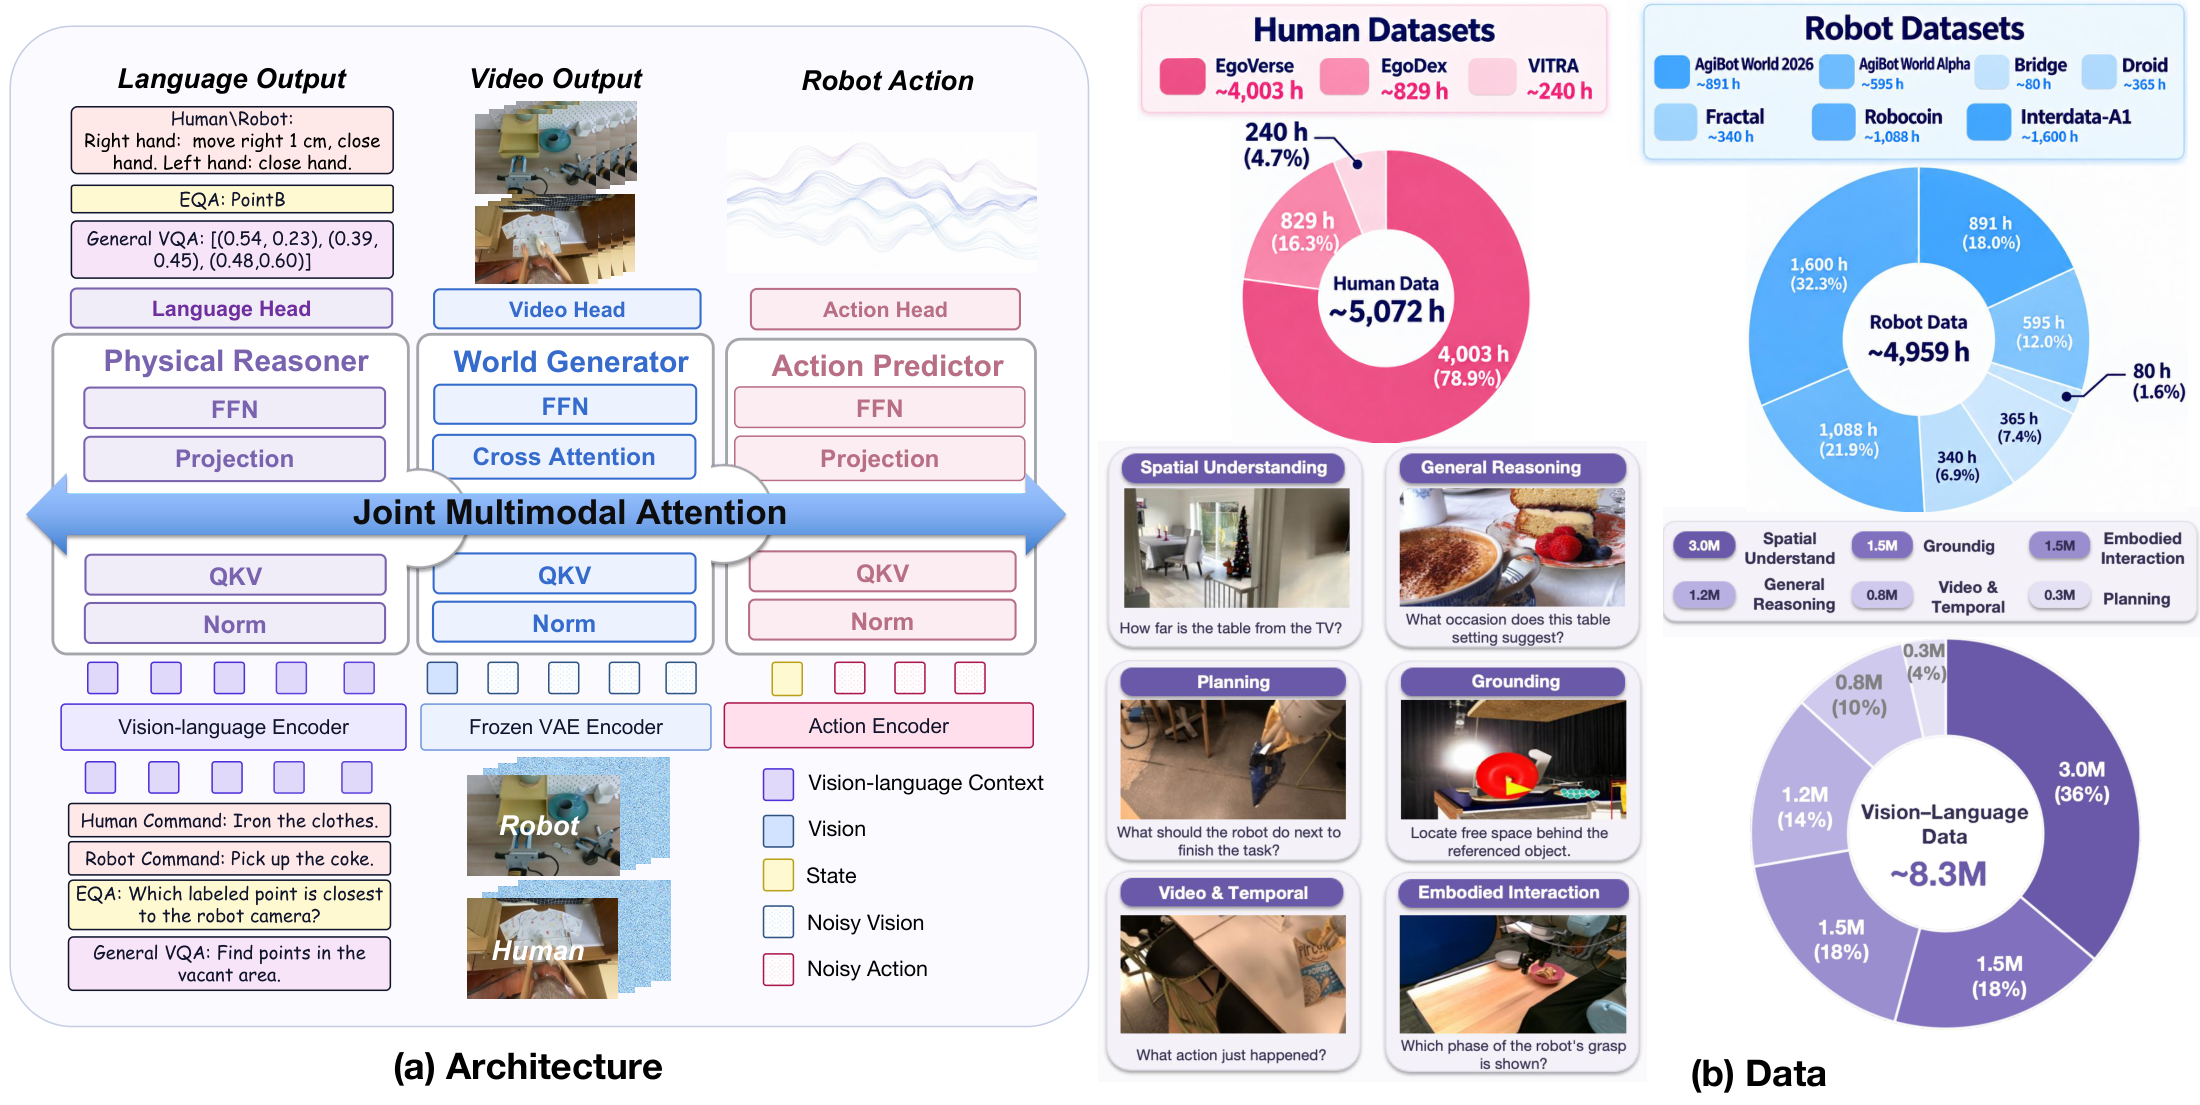
2026UniWAMUniWAM architecture with a physical reasoner, world generator, and action predictor
arXiv 2026 · Preprint

UniWAM: Unified World-Action Model

Core Contributor

A unified world-action model combining physical reasoning, future visual generation, and action prediction through a tri-modal architecture.

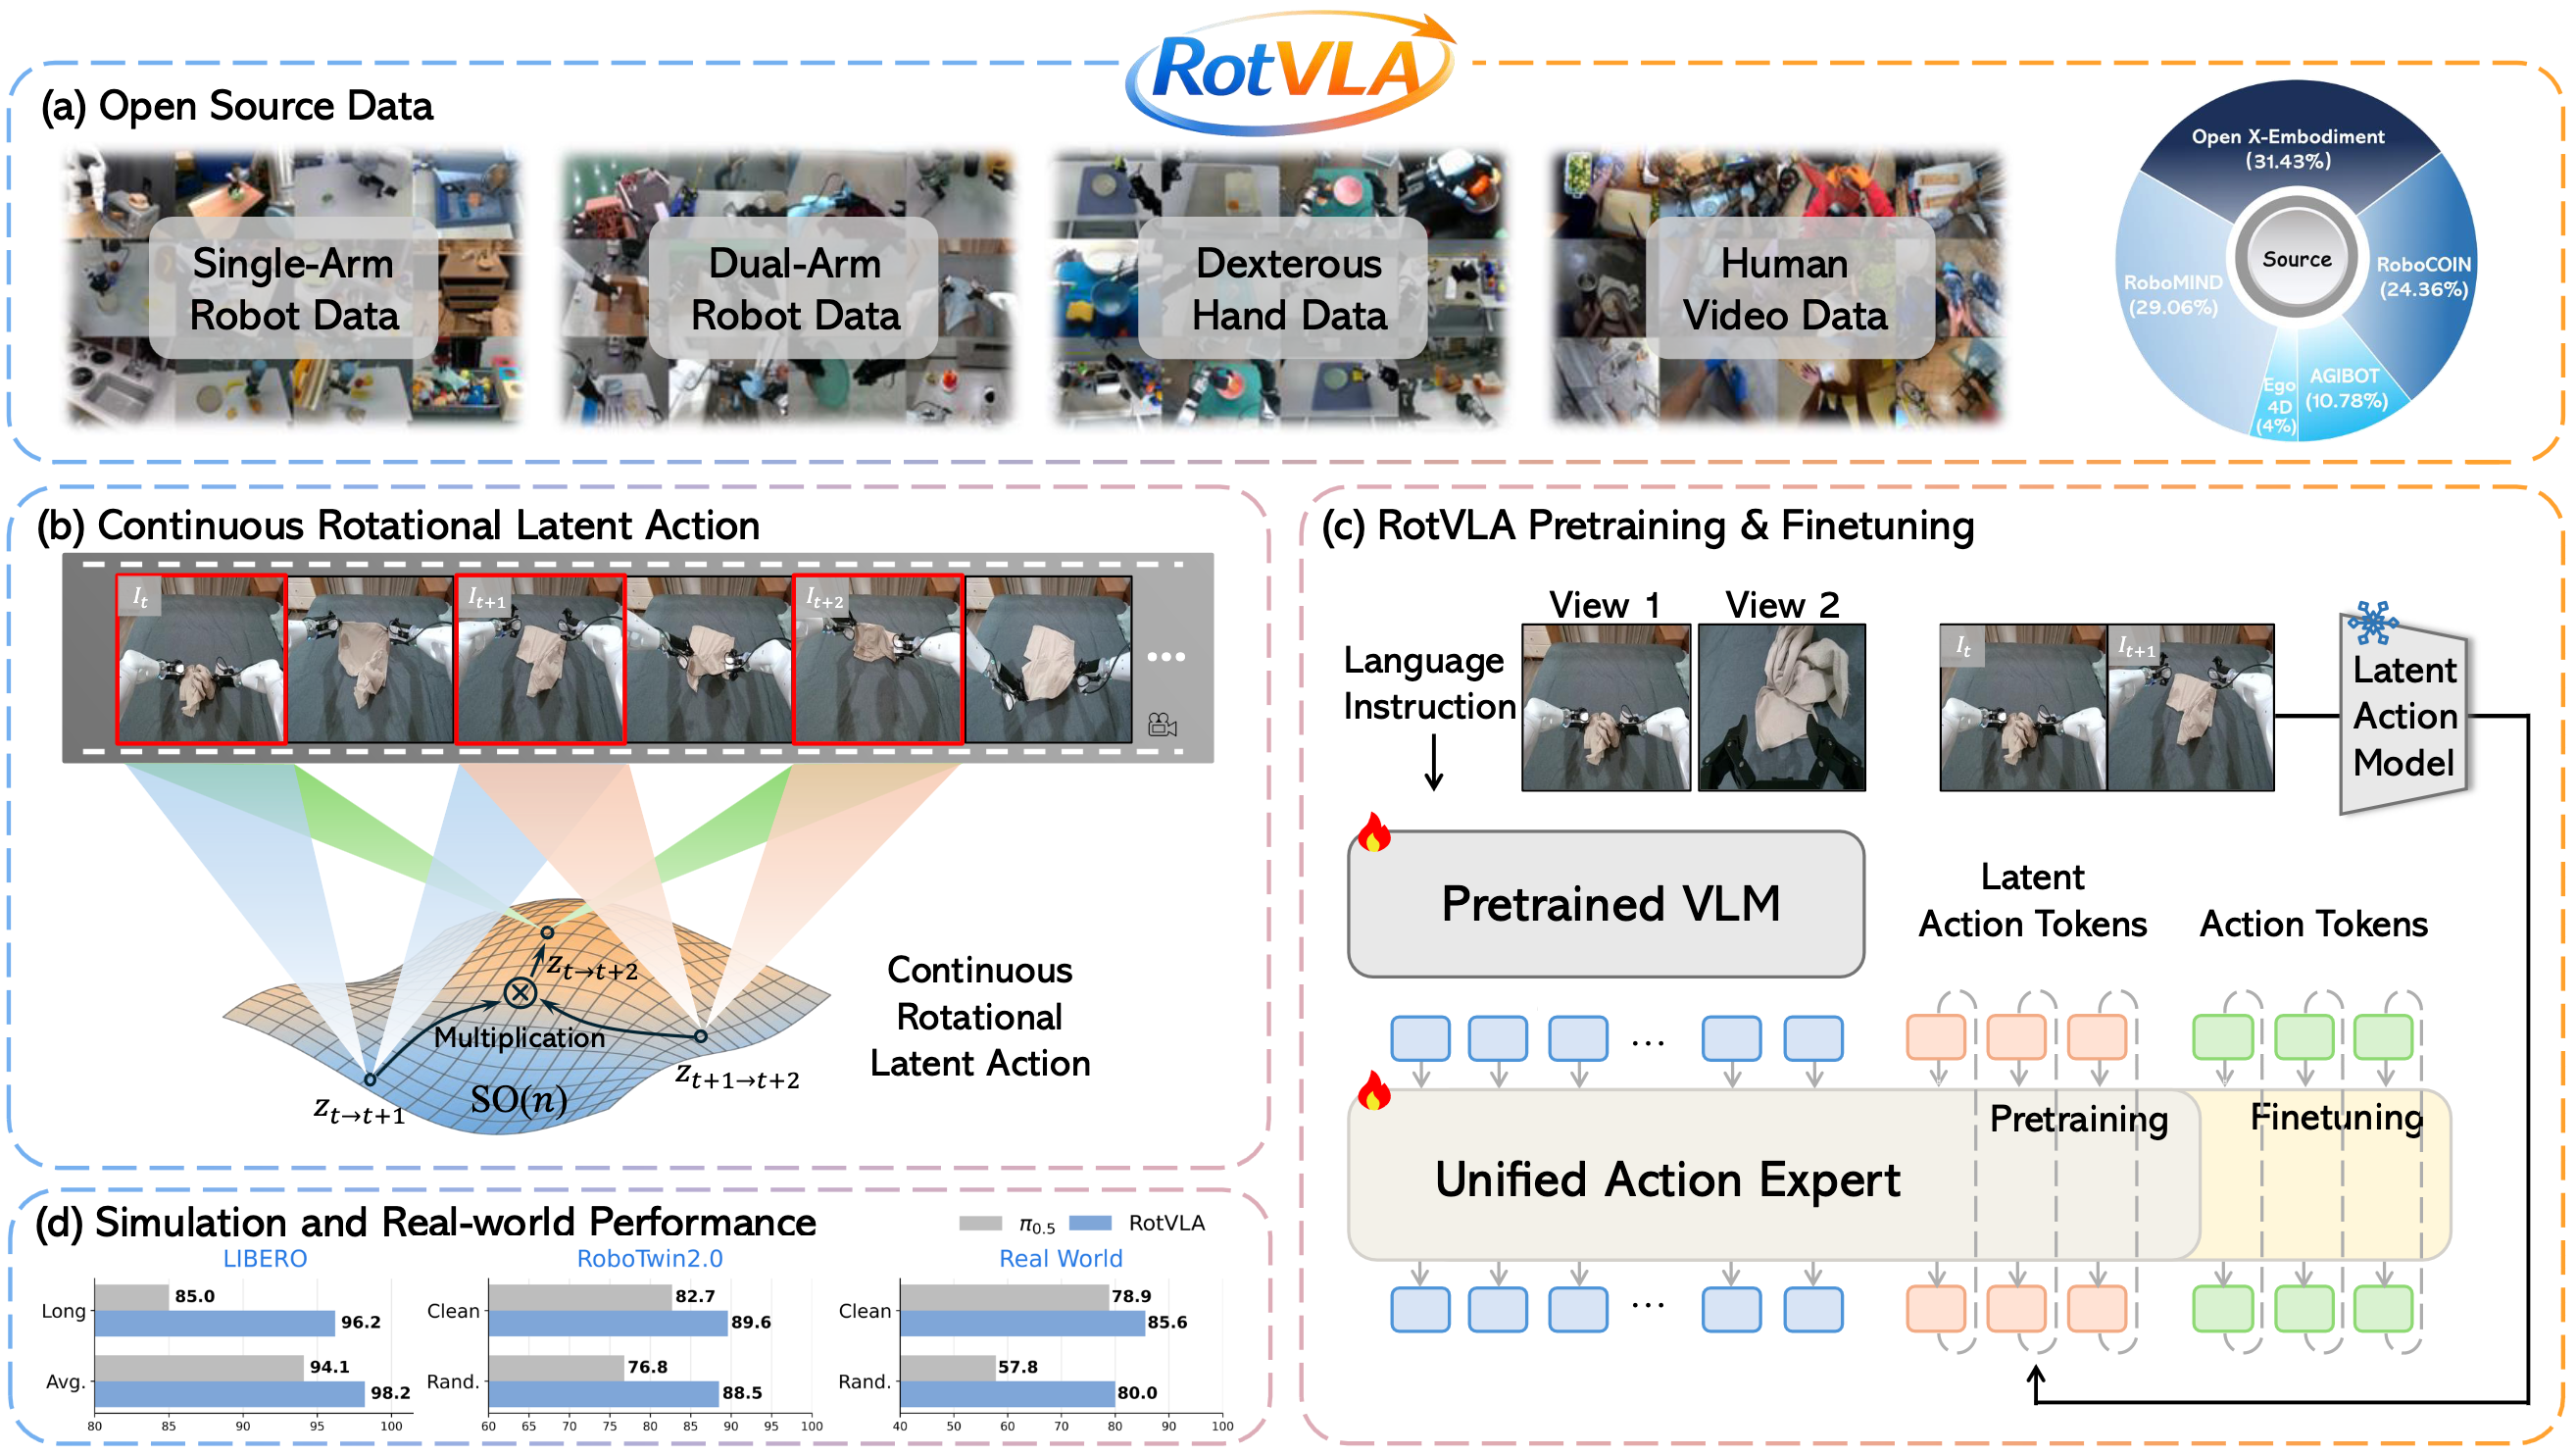
2026RotVLARotVLA overview: rotational latent actions, pretraining, and robot control
NeurIPS 2026 · Accepted

RotVLA: Rotational Latent Action for Vision-Language-Action Model

Qiwei Li, Xicheng Gong, Xinghang Li, Peiyan Li, Quanyun Zhou, Hangjun Ye, Jiahuan Zhou, Yadong Mu

Continuous rotational latent actions in SO(n) for compositional action representations and robotic manipulation.

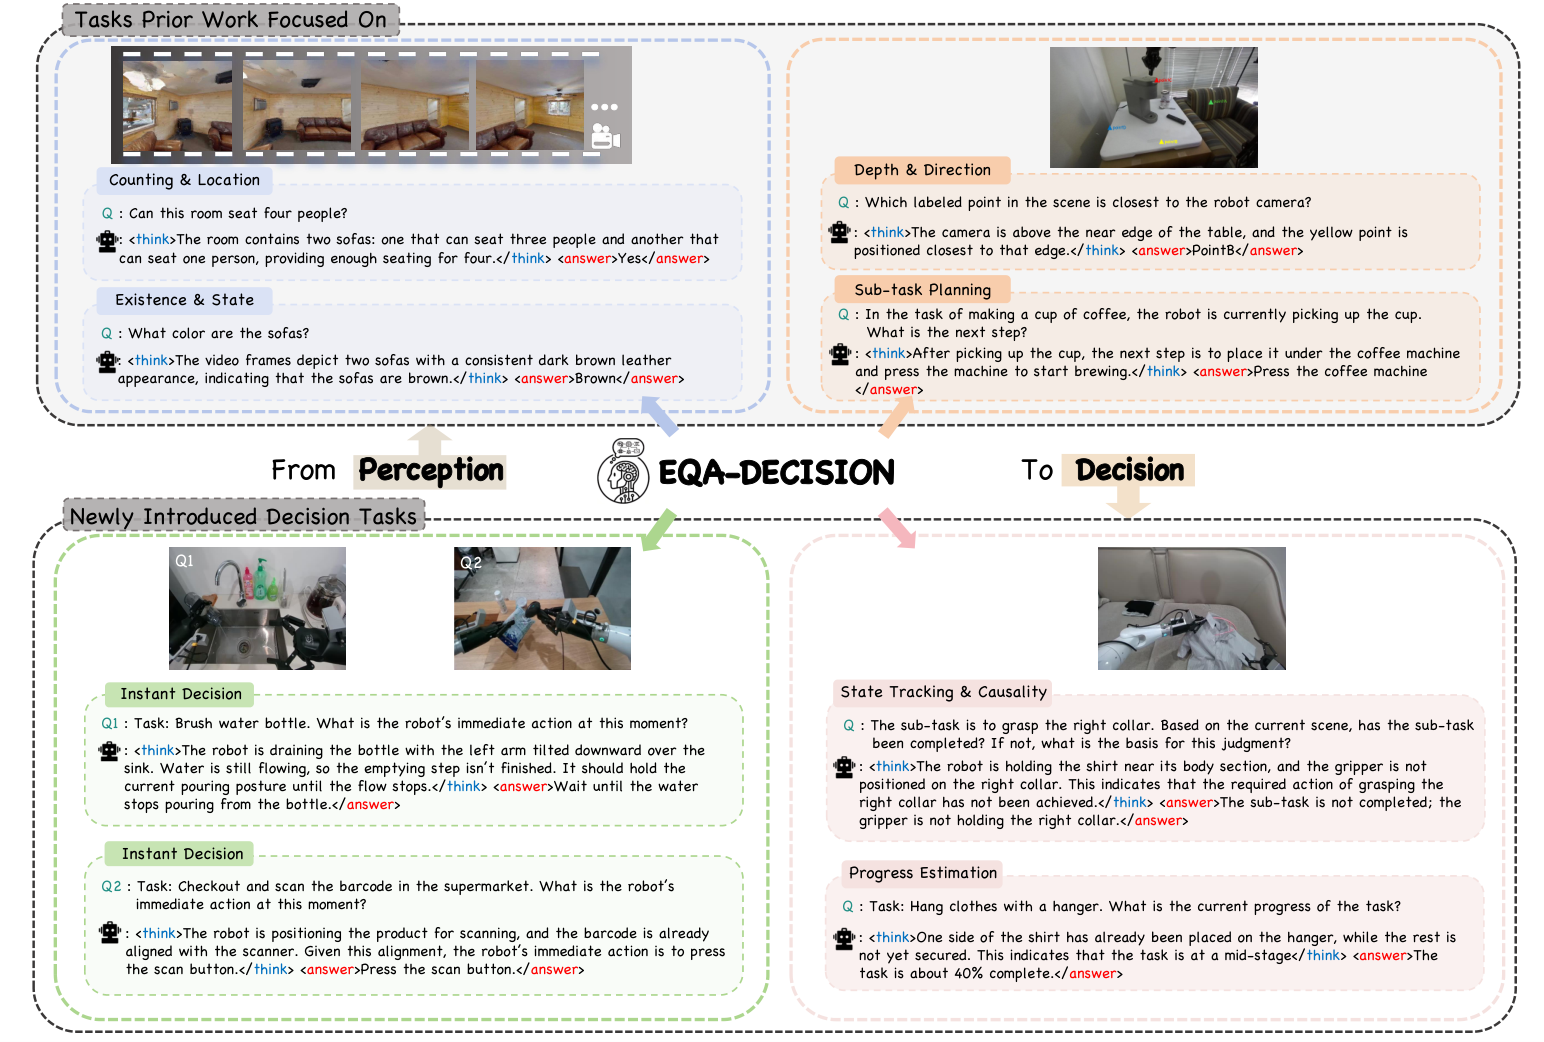
2026EQA-DecisionEQA-Decision examples spanning perception, reasoning, and decision-making
CVPR 2026

Extending Embodied Question Answering from Perception to Decision

Xicheng Gong, Qiwei Li, Peiran Xu, Yadong Mu

A large-scale embodied question-answering dataset and benchmark for perception, reasoning, and decision-making in dynamic environments.

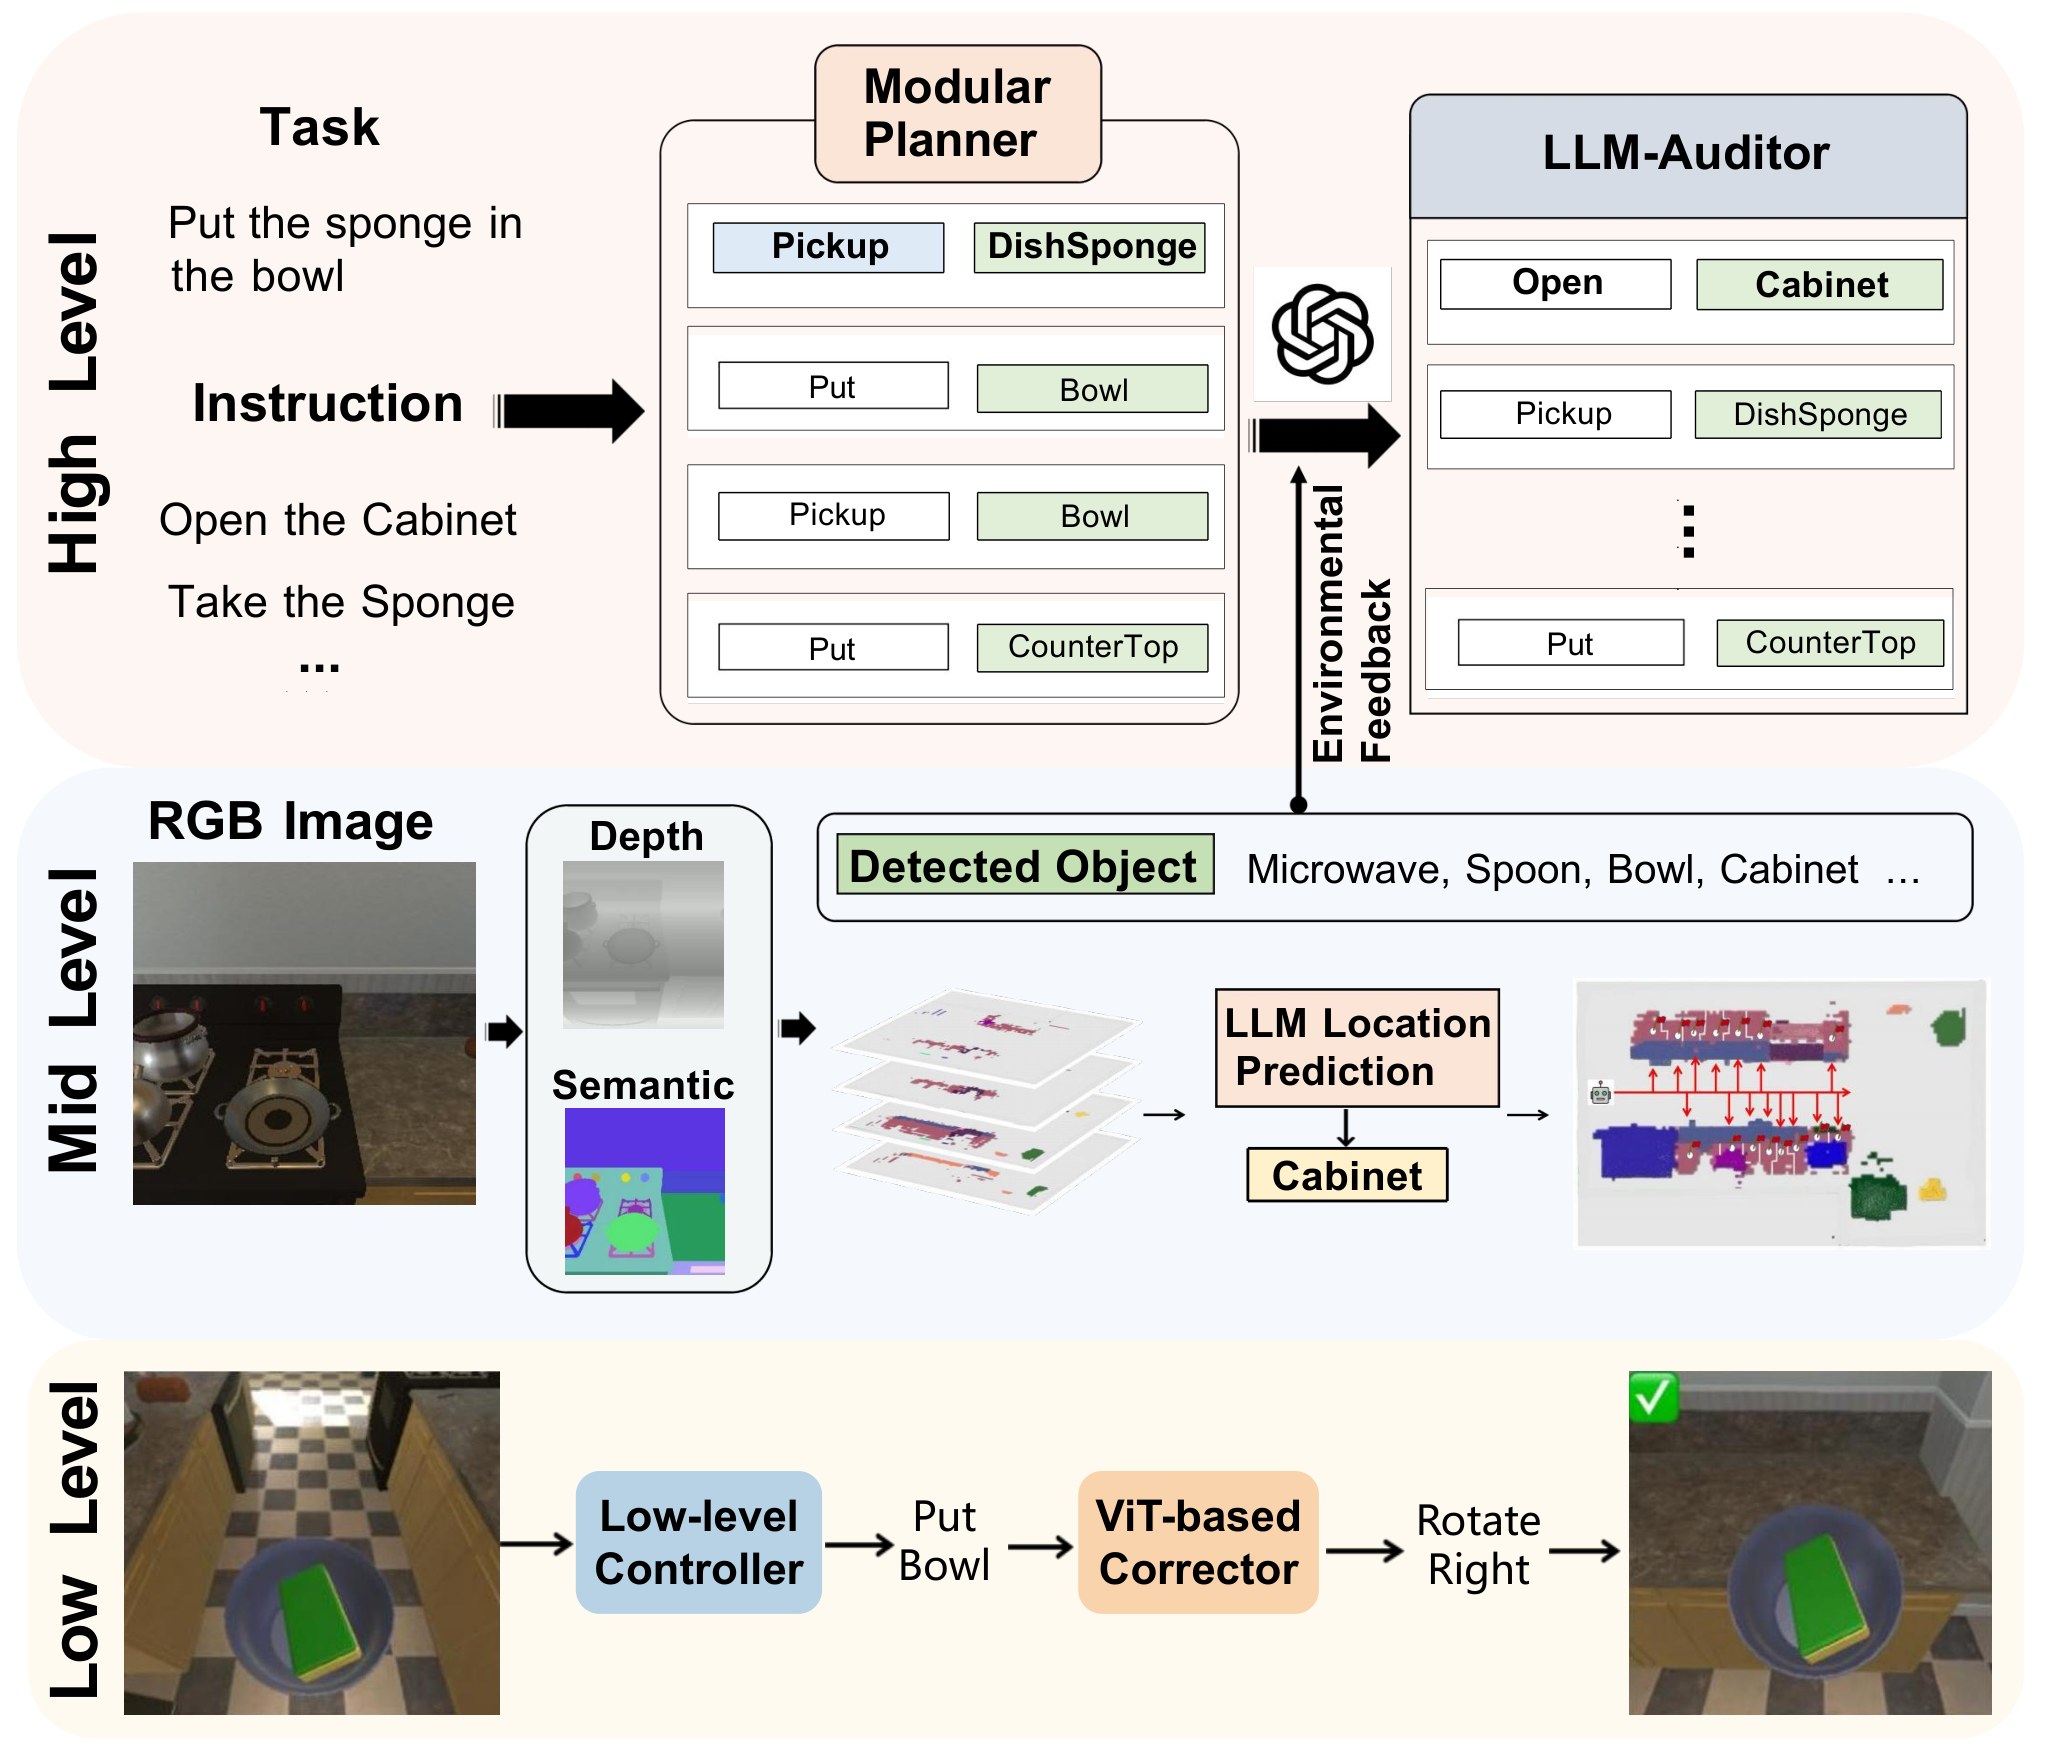
2026RePlan-BotRePlan-Bot overview of high-level planning, object reasoning, and low-level control
CVPR 2026 Workshop · GRAIL-V

RePlan-Bot: Multi-Level Replanning for Embodied Instruction Following

Xicheng Gong, Guozheng Sun, Peiran Xu, Yadong Mu

Multi-level replanning for embodied instruction following through online goal adjustment, structured exploration, and action correction.

Education

2023 — 2027

Peking University

B.E. in Intelligent Science and Technology

September 2023 – June 2027 (expected)

Contact

Feel free to reach out for research discussions and collaborations.